RAD AA
Autonomous Terminal Guidance
EDGE AI · COMPUTER VISION · GUIDANCE · FLIGHT CONTROL · EMBEDDED
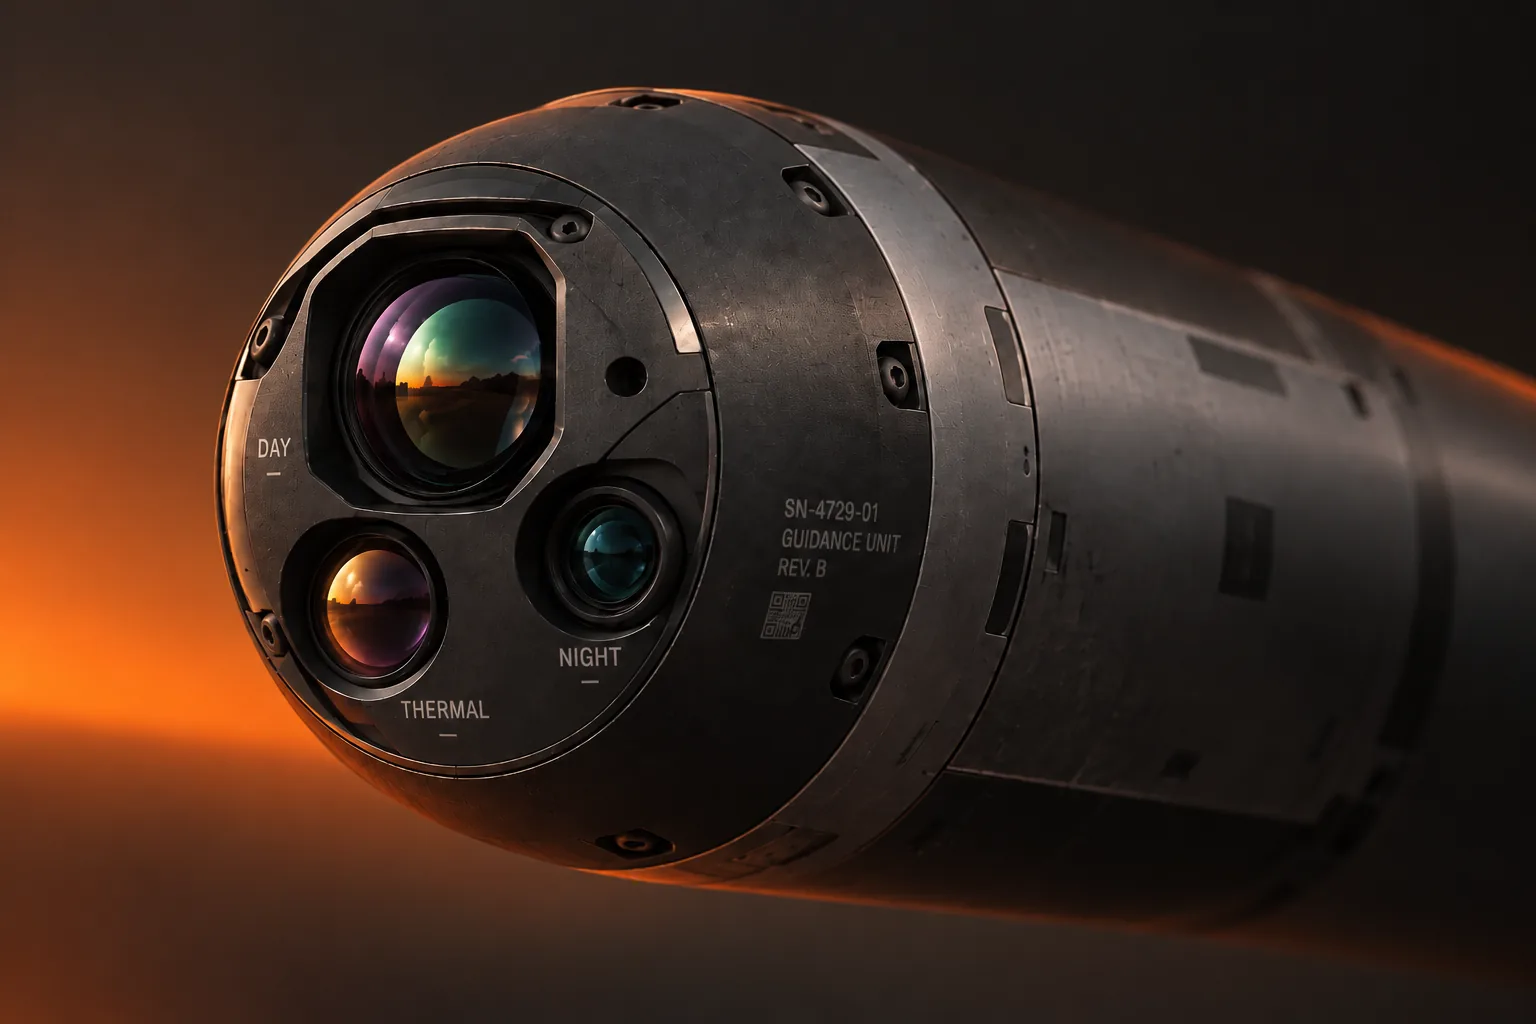
Embeddable onboard module for target detection, lock, tracking and flight correction during the terminal phase.
THE PROBLEM
Operator-in-the-loop guidance introduces latency that limits engagement of fast-moving targets, and depends on a control link that may not survive contested conditions. Moving detection and correction onto the airframe removes both constraints in the terminal phase.
THE SYSTEM
RAD AA is a guidance layer, not an airframe. The module performs detection, lock, tracking and flight correction onboard, and is designed to be embedded into existing carriers rather than to require a new platform.
SPECIFICATIONS
CURRENT CONFIGURATION
Funded development programme · Q4 2026 – Q3 2027
ARCHITECTURE POTENTIAL
Concept · not part of the current funded programme
Full specifications, interface documentation and test data are provided to verified counterparties under NDA.
REQUEST TECHNICAL DOSSIERENGINEERING DISCIPLINES
The in-house capabilities this project required.
- EDGE AI & COMPUTER VISIONOn-device inference, detection, classification, tracking and vision processing.
- EMBEDDED & FIRMWAREReal-time firmware, communication interfaces, device control and low-level system software.
- AUTONOMOUS SYSTEMS & CONTROLGuidance, control algorithms, sensor fusion and autonomous system functions.
- SYSTEM & PLATFORM INTEGRATIONIntegration with UAVs, vehicles, flight controllers, sensors, payloads and third-party systems.
WHAT HAS ACTUALLY BEEN CONFIRMED.
RAD AA is at bench validation. Its validation progression was defined before development began, and performance targets are kept separate from confirmed results throughout the programme.
0/6LEVELS CONFIRMED
- LEVEL 01IN PROGRESS
BENCH
Subsystem performance and basic functionality.
- LEVEL 02PLANNED
HARDWARE-IN-THE-LOOP
Interfaces, controls and behaviour under simulated conditions.
- LEVEL 03PLANNED
INTEGRATION
Complete system operating on the target platform.
- LEVEL 04PLANNED
FIELD
Performance in representative real-world environments.
- LEVEL 05PLANNED
OPERATIONAL
Evaluation against the intended use case with real operators.
- LEVEL 06PLANNED
COMBAT-CONDITION
Evaluation under actual operational conditions.